QMMK-P7

Multimodal Compatibility, Quadruped Mobility

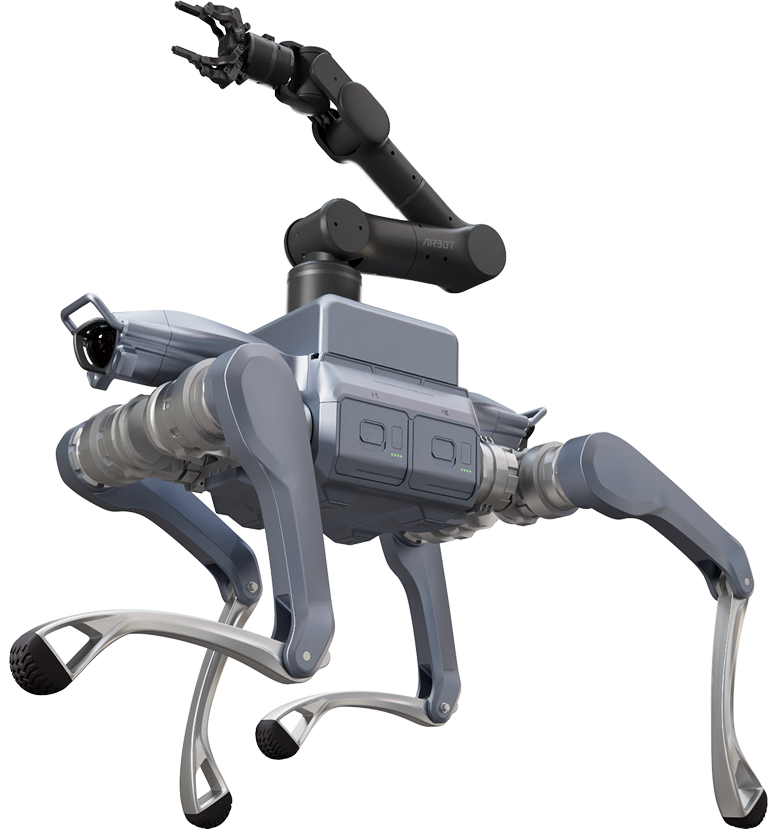
QMMK-P7 quadruped mobile manipulation platform
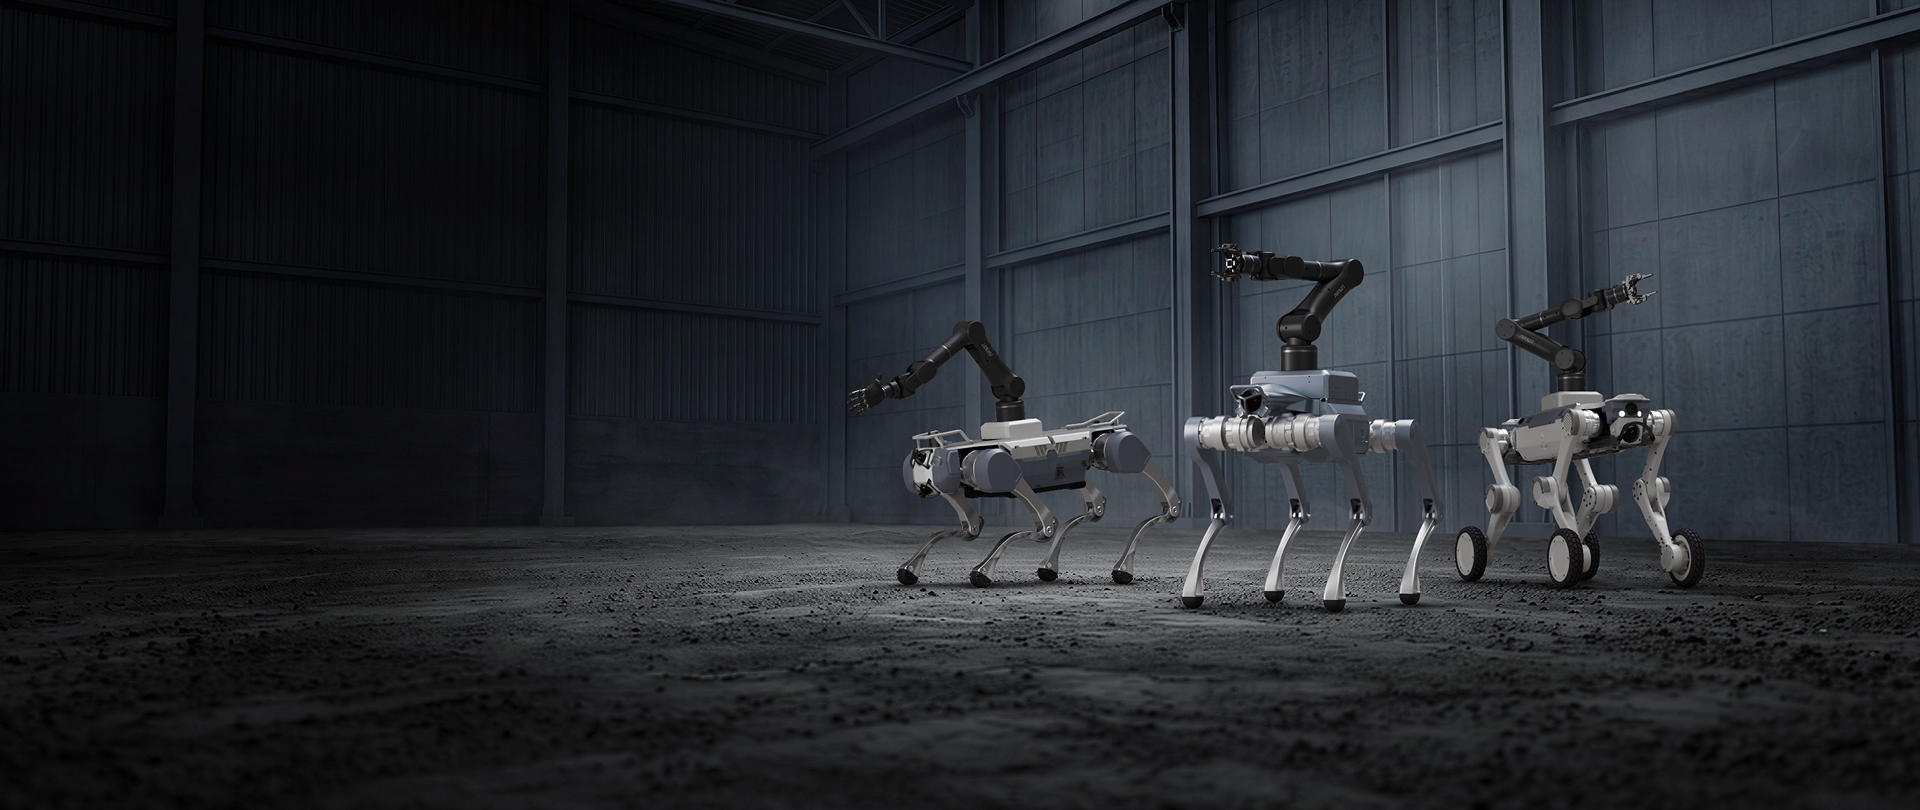
Compatibility with multiple quadruped robot platforms

Multi-Platform Compatibility, Rapid Deployment

Includes a standardized mounting kit for quick installation on leading quadruped robot platforms, including Unitree, DEEP Robotics, and Genisom AI. Supports dexterous hands from multiple brands, including Inspire, BrainCo, and AgiBot. Unifies control across connected devices through a proprietary all-in-one app. Enables wireless VR teleoperation over Wi-Fi and 4G, with millisecond-level responsiveness.
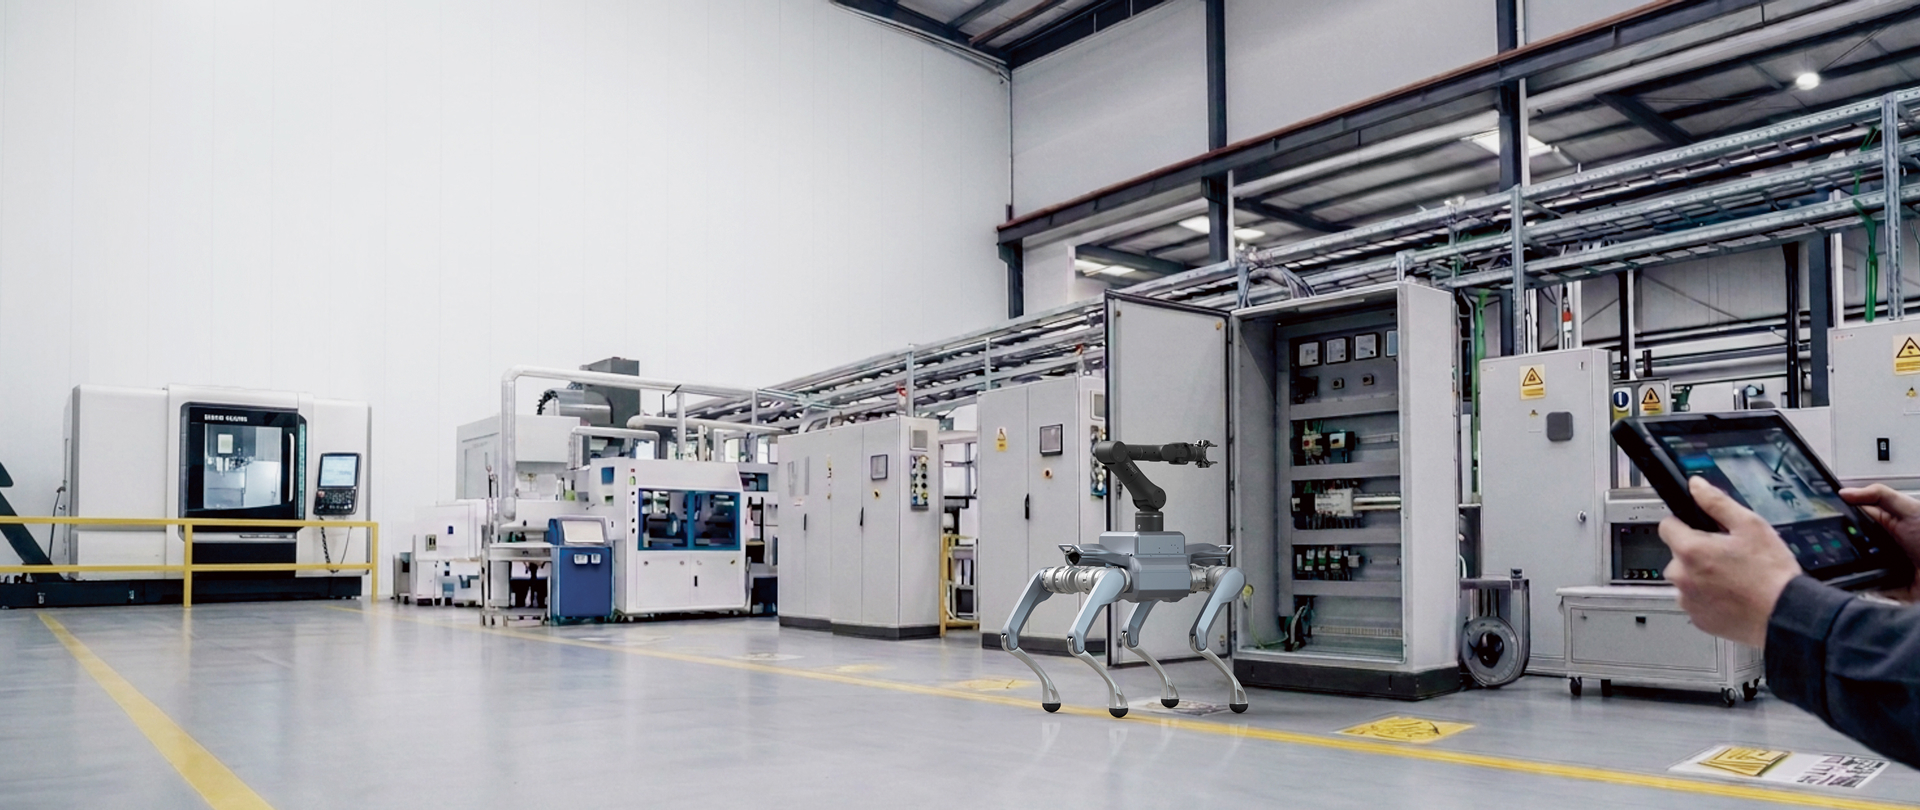
QMMK-P7 teleoperation in an industrial environment

Open Ecosystem, Developer-Friendly

Provides extensive hardware and software interfaces. Supports ROS 2, Python, and C++. Enables flexible integration of end effectors, cameras, and computing platforms. Streamlines research workflows and algorithm validation. Includes a ready-to-use teleoperation solution, with support for custom development of autonomous navigation and task-level reasoning.

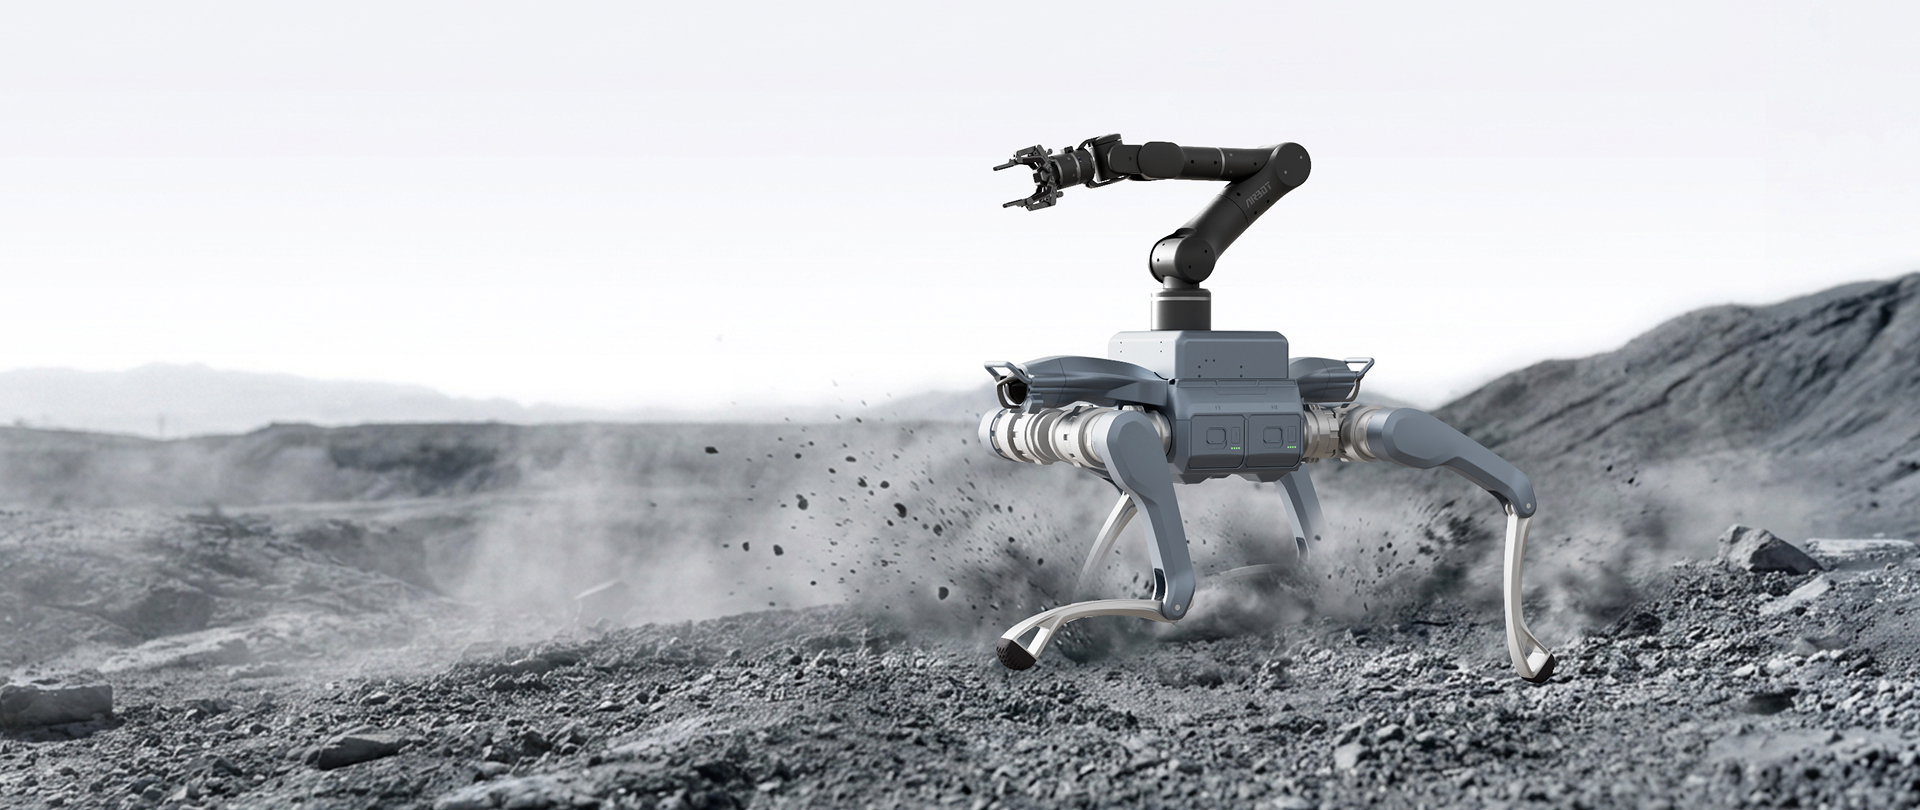
QMMK-P7 operating across challenging terrain

All-Terrain Mobility, Flexible Operation

Compatible with multiple quadruped platforms for operation across challenging terrain and in hard-to-reach environments. Performs on-site manipulation tasks, including grasping, carrying, and button pressing. Combines quadruped mobility with robotic manipulation for versatile field operations.

Multi-Scenario Applications

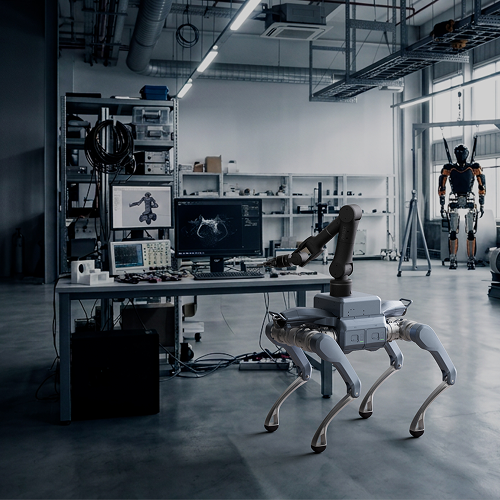
QMMK-P7 research exploration scenario

Research and Development

Supports robotics research, algorithm development, and embodied AI experimentation.

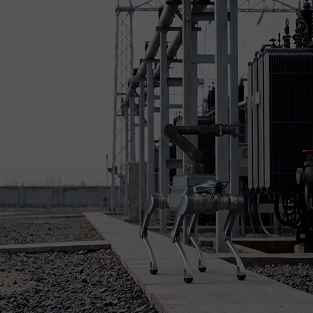
QMMK-P7 power inspection scenario

Power Inspection and Maintenance

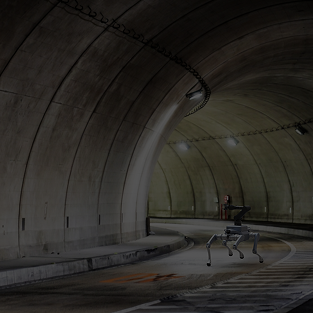
QMMK-P7 utility tunnel scenario

Utility Tunnels and Underground Infrastructure

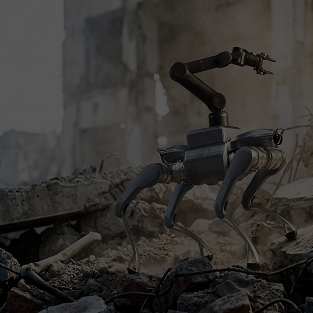
QMMK-P7 emergency rescue scenario

Emergency Response and Rescue

Key Specs

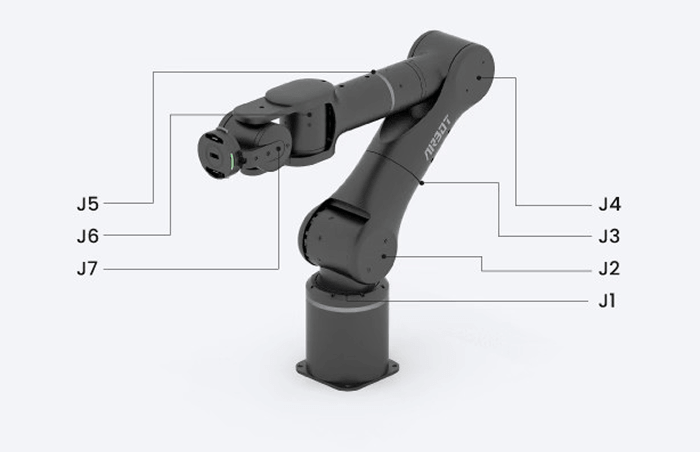
AIRBOT P7

DoF7
Weight5kg
Payload3kg
Maximum Reach640 mm
MaterialsAluminum Alloy / Plastic
Repeatability± 0.1 mm
Control ModesPosition, Torque, and Velocity
Standard Power Adapter48 V / 5 A
Power Consumption60 W
SDKC++, Python
External InterfacesUSB Type-C 3.0, USB Type-C 2.0, RS485, CAN FD, Ethernet
AI Inference Compute10 TOPs
CommunicationCAN FD / TCP
ProtectionIP54
Joint BrakingJ1-J4: Mechanical Braking J5-J7: Servo Braking
Temperature-10 ~ 55 °C

Joint Motion Range

AIRBOT P7 joint diagram
No.Range of MotionMax. Joint Speed
J1[-170°, 170°]180°/s
J2[48°, -148°]180°/s
J3[-170°, 170°]180°/s
J4[-145°, 5°]180°/s
J5[-170°, 170°]360°/s
J6[-45°, 45°]360°/s
J7[-90°, 70°]360°/s

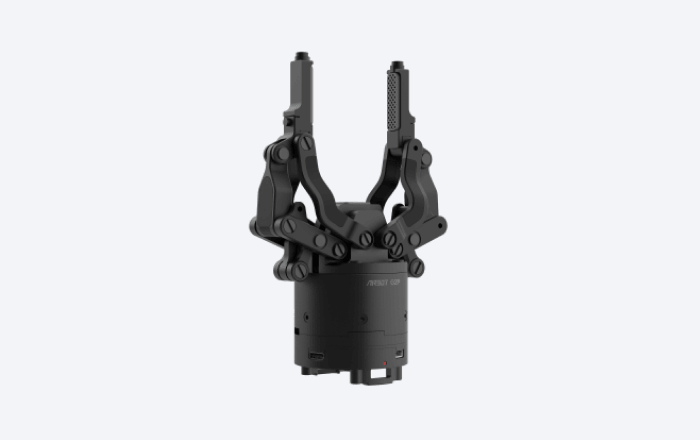
AIRBOT G2P

AIRBOT G2P two-finger gripper
Gripping Range0~95 mm
Max. Gripping Force30 N
Weight408 g
MaterialAlloy Aluminum
CommunicationCAN
Power InputDC24 V
Power Consumption36 W
Control Frequency250 Hz
InstallationQuick-Release
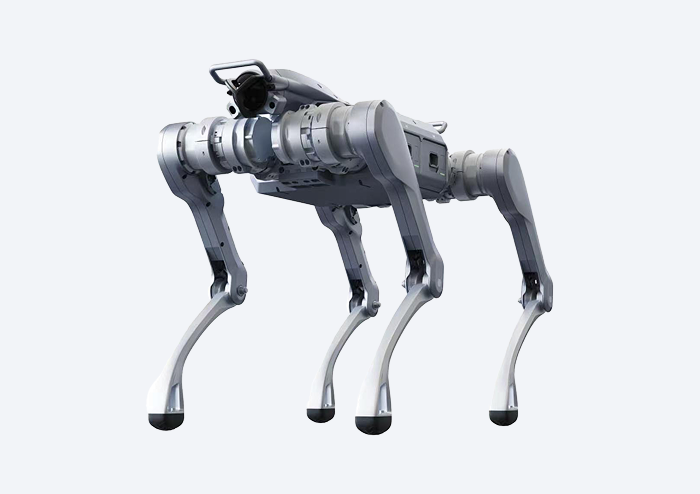
ProductUnitree A2
Weight (with battery)42 kg
Degrees of Freedom (Joint Motors)12
Max Joint TorqueAbout 180 N·m
Supply Voltage50.4 V
Speed0–3.7 m/s (Up to ~5 m/s)
Ingress Protection RatingIP56
Continuous Walking PayloadAbout 25 kg (Ideally, it can reach approximately 35 kg.)
Control & ComputeStandard: 8-Core high-performance CPU (platform) + Intel Core i7 (user development)
AccessoryA2-P7 Adapter Plate, A2-P7 Front & Rear Covers, Support Posts

Unitree A2

Unitree A2 quadruped mobile platform

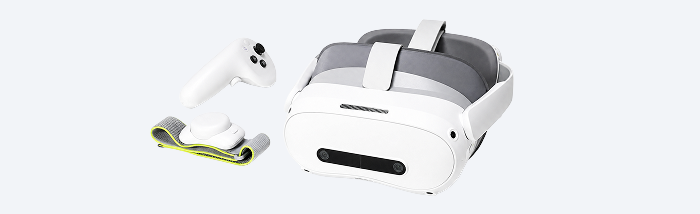
Pico4 Ultra Enterprise

Pico teleoperation control kit
ProductPico4 Ultra Enterprise
ProcessorQualcomm Snapdragon XR2+ Gen 1
Memory and Storage12 GB LPDDR5 RAM + 256 GB UFS Storage
Network ConnectivityNetwork Adapter & Ethernet Cable
SoftwareVR Teleoperation App Developed by DISCOVER Robotics